Youngjin HongI develop robot learning methods that connect vision-language reasoning with reliable physical execution. Seeking a 2027 research internship I am a PhD student in the Department of Electrical and Computer Engineering at University of Minnesota (UMN), advised by Prof. Changhyun Choi. In the Choice Robotics Lab at the Minnesota Robotics Institute (MnRI), I study Vision-Language-Action models, generative policies, and contact-rich manipulation. From May to September 2026, I was a research intern on the Optimization & Robotics Team at Mitsubishi Electric Research Laboratories (MERL). I developed learning-based methods for robotic disassembly under pose uncertainty, integrating learned manipulation policies with compliant control and evaluating them on an industrial robot. Before joining UMN, I was a research engineer at Hanwha Aerospace (January–July 2024), where I built Isaac Sim environments and supported field testing for autonomous unmanned ground vehicles. I completed my master's and bachelor's in Mechanical Engineering at Sungkyunkwan University (SKKU), advised by Hyungpil Moon. |
|
Under Review |
|
Nominal vs. corrected actions |
NUDGE: Efficient Structured Action Correction for Vision-Language-Action Models under Latency
Youngjin Hong, Tian Xie, Mingen Li, Hantao Ye, Ross Worobel, Houjian Yu, Yang Zhao, Changhyun Choi Submitted to ICRA 2027 Corrects delayed VLA actions using current feedback while keeping the base policy frozen. |
|
6× speed |
POINTCAST: One World Model for Rigid, Articulated, and Deformable Object Manipulation
Hantao Ye, Ross Worobel, Zhuoli Xie, Mingen Li, Houjian Yu, Youngjin Hong, Changhyun Choi Submitted to ICRA 2027 Project Page A shared world model predicts object motion across rigid, articulated, and deformable manipulation. |
Publications |
|
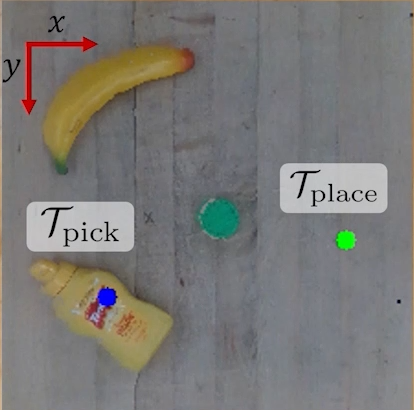
LACY: A Vision-Language Model-based Language-Action Cycle for Self-Improving Robotic Manipulation
Youngjin Hong*, Houjian Yu*, Mingen Li, Changhyun Choi (*Equal Contribution) ICRA, 2026 arXiv | Project Page A bidirectional language–action cycle learns action-to-language and language-to-action mappings, with a semantic consistency verifier that filters self-generated samples for reliable self-improvement. |
|
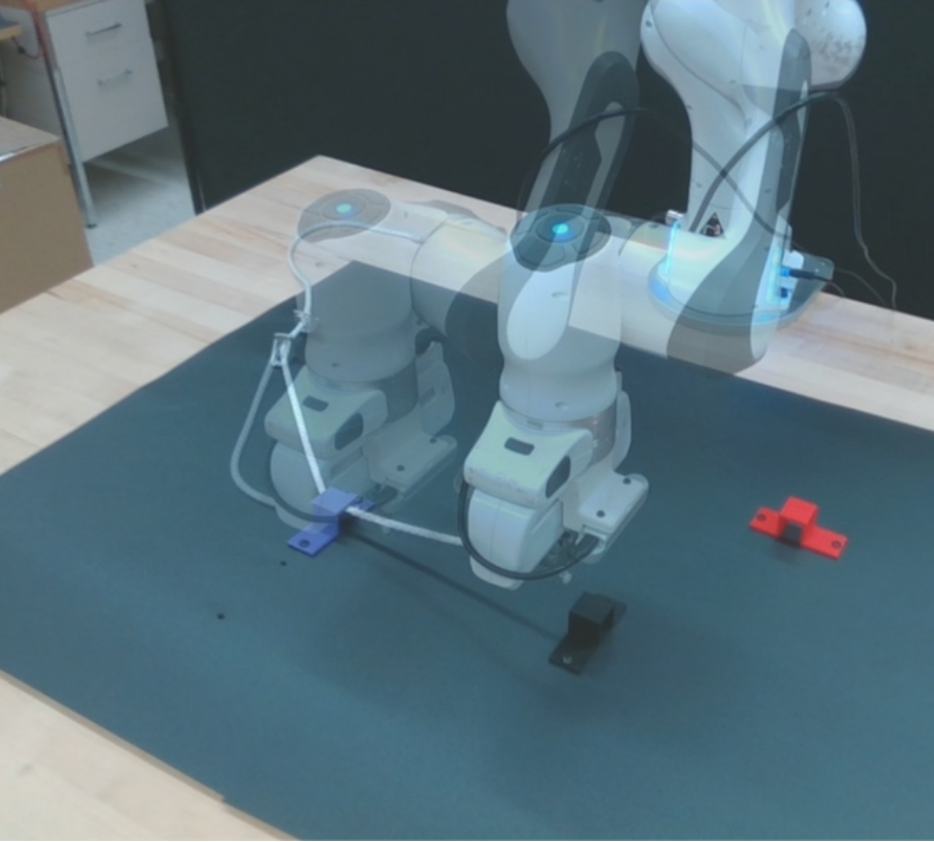
Hierarchical DLO Routing with Reinforcement Learning and In-Context Vision-language Models
Mingen Li, Houjian Yu, Yixuan Huang, Youngjin Hong, Changhyun Choi ICRA, 2026 · Best Paper Award on Robot Learning Finalist arXiv | Project Page Combines reinforcement learning and in-context vision-language reasoning for hierarchical routing of deformable linear objects. |
|
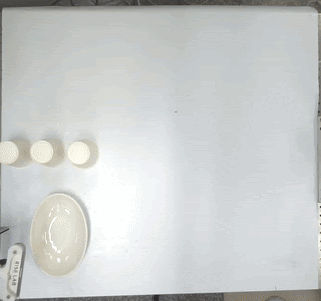
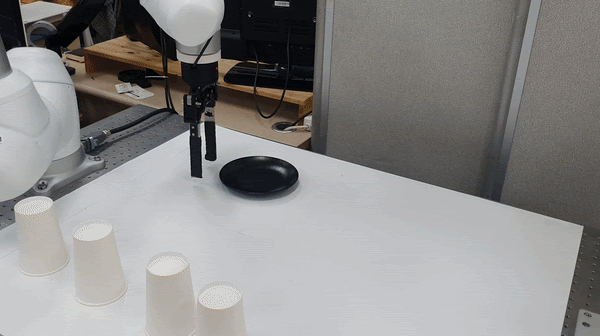
Vision-based Stable 2D Planar Pushing of Dishware with 6-DOF Manipulator
Youngjin Hong, Hong-ryul Jung, Sungwon Seo, Jeongmin Jeon, Jonghyun Kim, Hyungpil Moon ECCOMAS, 2023 Paper | Project Page |
|
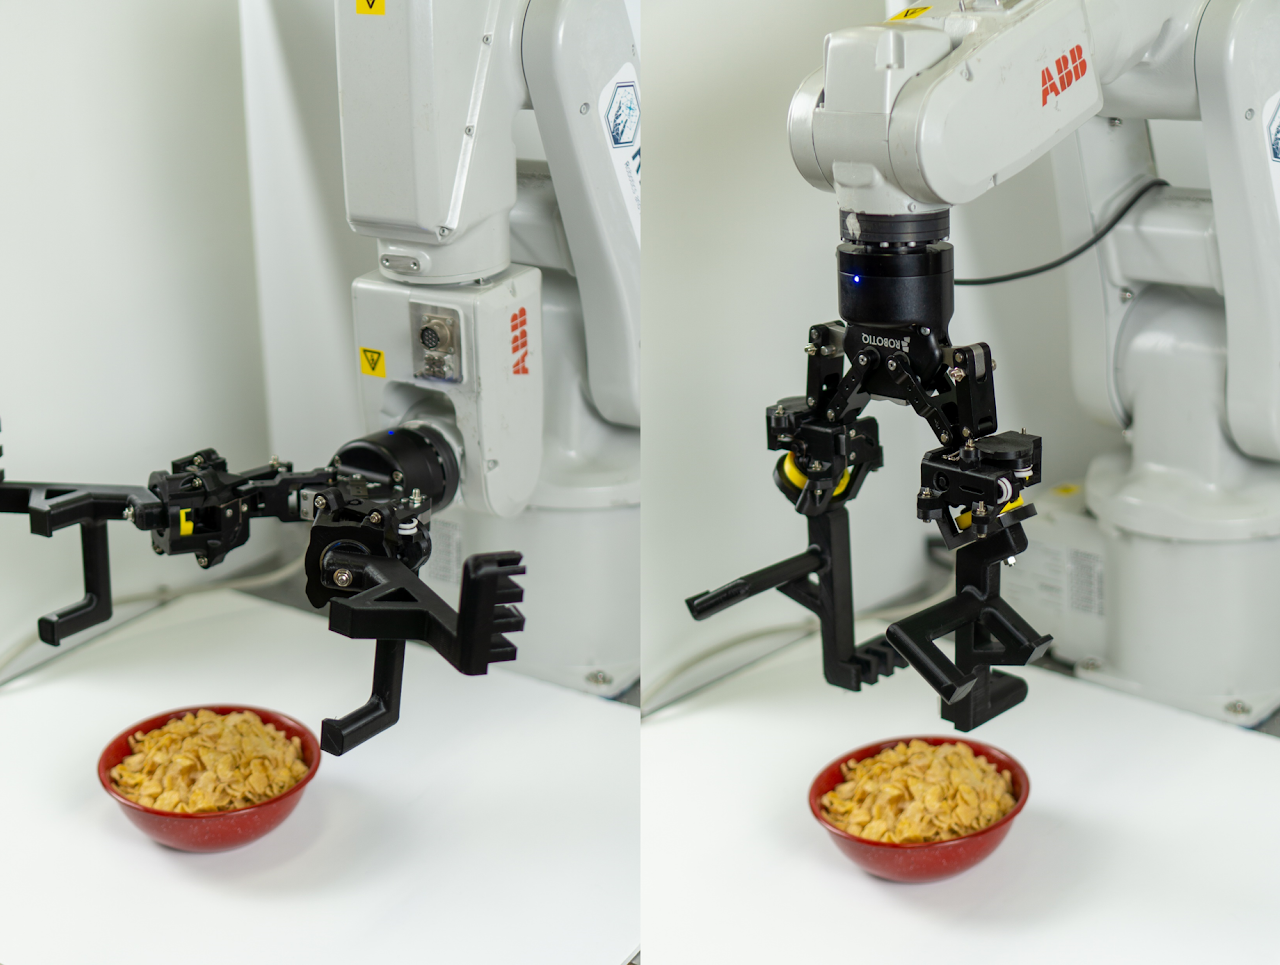
Passive Transformable Fingertip to Augment Tableware Grasp Capability
Haejoon Seong*, Youngjin Hong*, Hong-ryul Jung*, Myeongyun Doh* (Equal Contribution), Jonghyun Kim, Hyungpil Moon ICCAS, 2022 Paper | Project Page |
Selected Projects |
|
4× speed |
VLM-Guided Person Re-Identification and Tracking
Collaboration with ETRI · September 2025–Present Video A language-guided person tracking pipeline integrating YOLOv11-L, ByteTrack, and LLaVA-NeXT to identify and re-identify a described target in continuous video. An adaptive triggering mechanism invokes VLM reasoning during initialization, target loss, low-confidence tracking, or periodic verification. |
Talks and Presentations |
|
Bridging Language-Action Reasoning and Physical Execution in Robotic Manipulation
Youngjin Hong Invited Talk at Sungkyunkwan University (SKKU), 2025 Youtube |
|
Stable Dishware Pushing via Convolutional Neural Networks
Youngjin Hong, Sungwon Seo, Hong-ryul Jung, Jeongmin Jeon, Jonghyun Kim, Hyungpil Moon IROS, 2023 (Poster, Late Breaking Results) Project Page |
Academic ServicesReviewer for IROS, CoRL, CPHS 2026 Workshop, and IEEE Robotics and Automation Letters (RA-L). |